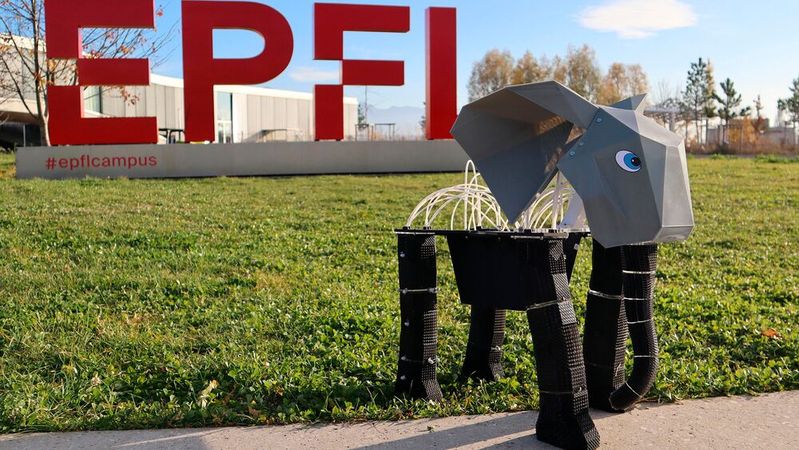
Researchers at EPFL have developed a programmable lattice structure for robotics that can be 3D-printed and mimics the vast variety of biological tissues—from flexible body stems to rigid bones—using a single foam material.
The EPFL team has developed a lattice structure that combines the diversity of biological tissues with robotic control and precision. The result is an elephant robot with a soft trunk that can twist, bend, and rotate, as well as stiffer hip, knee, and ankle joints.
(Image: EPFL)
The powerful sprint of a cheetah, the smooth glide of a snake, or the skillful grip of a human: all of this is made possible by the seamless interaction of soft and solid tissues. Muscles, tendons, ligaments, and bones work together to provide the energy, precision, and freedom of movement necessary for the complex motions throughout the animal kingdom.
Replicating this diversity of the musculoskeletal system in robotics is a tremendous challenge. So far, 3D printing with multiple materials has enabled the creation of soft-rigid robots. While this approach can mimic the diversity of biological tissues, it means that crucial properties such as stiffness or durability cannot be continuously controlled across the entire robot structure.
Now, a team led by Josie Hughes from the Computational Robot Design and Fabrication Lab (CREATE) at EPFL’s School of Engineering has developed a lattice structure that combines the diversity of biological tissues with robotic control and precision. The lattice, made from a simple foam, consists of individual units (cells) that can be programmed to take on different shapes and positions. These cells can adopt over a million different configurations and even be combined into infinite geometric variations.
Construction of Lightweight, Adaptable Robots
"We used our programmable lattice technology to build a musculoskeletal-inspired elephant robot with a soft trunk that can twist, bend, and rotate, as well as stiffer hip, knee, and foot joints," says postdoctoral researcher Qinghua Guan. "This demonstrates that our method provides a scalable solution for designing unprecedentedly lightweight, adaptable robots." The research findings were recently published in Science Advances.
The team's programmable lattice can be printed with two main cell types with different geometries: the body-centered cubic (BCC) cell and the X-Cube. When each cell type is used for the 3D printing of a robotic "tissue," the resulting lattice exhibits different stiffness, deformation, and load-bearing properties. However, the CREATE Lab's method also allows for printing lattices from hybrid cells whose shape lies somewhere between BCC and X-Cube.
"This approach enables the continuous spatial blending of stiffness profiles and allows for an infinite range of blended unit cells. It is particularly well-suited for mimicking the structure of muscle organs like an elephant trunk," says doctoral student Benhui Dai.
In addition to modulating the shape of each cell, the scientists can also program its position within the lattice. This second programming dimension allows them to rotate and translate each cell along its axis. The cells can even be stacked on top of each other to create entirely new cell combinations, giving the resulting lattice an even broader range of mechanical properties. To give an idea of the virtually infinite range of possible variations: a lattice cube with four stacked cells can yield around 4 million possible configurations, while five cells result in over 75 million configurations.
Gallery
Complex Movement of the Muscular Elephant Trunk Replicated
For their elephant model, this dual programming capability enabled the creation of various tissue types with unique ranges of motion, including a sliding joint (found in the small bones of the foot), a uniaxial bending joint (found in the knee), and a biaxial bending joint (found in the toes). The team was even able to replicate the complex movement of an elephant's muscular trunk by developing separate lattice sections for twisting, bending, and rotational movements, ensuring smooth and continuous transitions between them.
Hughes says that their foam lattice technology offers many exciting possibilities for future robotics research beyond modifying the foam material or incorporating new cell shapes. "Like a honeycomb, the lattice's strength-to-weight ratio can be very high, enabling extremely lightweight and efficient robots. The open foam structure is well-suited for movement in fluids and even offers the potential to integrate other materials, such as sensors, into the structure to imbue the foams with additional intelligence."
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.