Deep Robotics is sending a modified four-legged robot to the Arctic. Instead of wheels, the system uses bionic paws to move safely across fragile ice floes. The technology is designed to facilitate dangerous research expeditions.
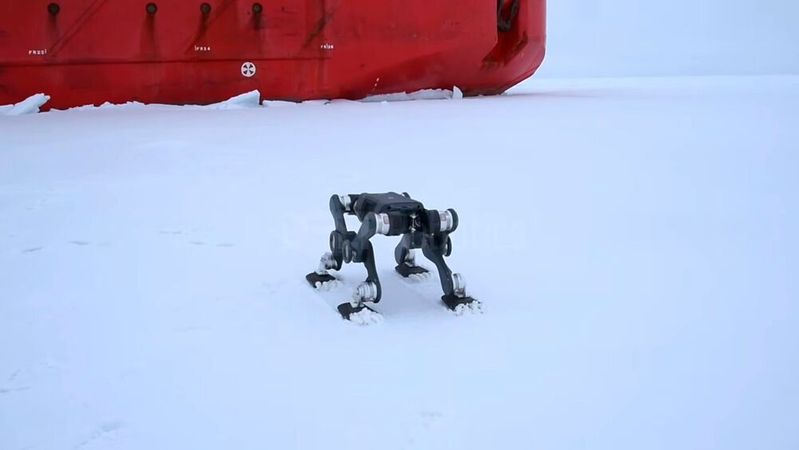
Mission in the Arctic Ocean: A Deep Robotics Lynx S10 quadruped robot maneuvers across the pack ice in the Arctic Ocean and leaves the research icebreaker.
(Image: Deep Robotics)
The Chinese manufacturer Deep Roboticshas sent a specially adapted version of its four-legged Lynx S10 robot on an expedition to the Arctic. The goal of the mission, in which the approximately 44 pounds system was deployed onto ice floes from a research vessel, was to test its mobility and reliability under extreme climatic conditions. In its standard configuration, the Lynx S10 is designed as a wheel-leg hybrid. This design typically allows the machine to conserve energy by rolling on flat terrain and to switch to a running mode in rough terrain.
However, the conventional wheel design proved inadequate for the harsh environment of the Arctic Ocean. Wheels find it difficult to gain traction on smooth, wet ice or in deep snow and quickly sink under load. To ensure mobility in the polar region, the engineers therefore fundamentally modified the robot. The most striking and important change concerns the locomotion elements: The developers replaced the conventional wheel modules at the ends of the four legs with large, biomimetic paws. These are modeled after the morphology of polar bear paws. The design distributes the robot’s weight over a significantly larger surface area, effectively preventing the machine from sinking into soft snow or breaking through thin ice crusts.
Gallery
Swimming Aids And Higher Protection Rating
To ensure the necessary grip on hard, slippery ice, the designers equipped the robotic legs with a non-slip surface texture and integrated claws that function similarly to crampons. In addition, the team increased the surface area of the leg sections. This allows them to function as paddles when necessary, should the robot need to move through areas of mixed ice and water. To ensure the machine’s buoyancy when wading through deep puddles of meltwater, air-filled buoyancy chambers were additionally attached to the upper limbs.
In addition to the mechanical design, the manufacturer also adapted the hardware’s durability to the extreme environmental conditions. While the standard versions of the robot are protected against dust and water jets to IP54 or IP66, depending on the model, the developers upgraded the sealing of the Arctic prototype to protection class IP67. The housing is thus protected against moisture ingress even if temporarily submerged in icy water. Since the standard operating range of the Lynx S10 typically ends at minus 4 degrees Fahrenheit, the team also integrated special insulation and cold-weather protection components. These protect the electronics and batteries from malfunctioning due to extreme sub-zero temperatures.
Autonomous Navigation in Drift Ice
Navigation across unpredictable and sometimes treacherous terrain is largely autonomous. The robot relies on AI-based motion control. This system was further developed in collaboration with Sun Yat-sen University, Westlake University, and Hangzhou Dianzi University to optimize the paw geometry and control algorithms for ice. A special algorithm continuously analyzes the ground conditions and selects the appropriate gait. The spectrum ranges from cautious probing on brittle ice to powerful wading through slush.
The Lynx S10 uses several systems for navigation in the wilderness:
four HDR ultra-wide-angle cameras for high-contrast images that enable precise obstacle detection
Front and rear lidar sensors for real-time 3D mapping of the surroundings
a tilt function to view the terrain from a higher vantage point when necessary
During tests on Arctic drift ice, the system demonstrated its ability to navigate unstable surfaces and areas of mixed ice and water. The robot’s legs and claws kept it stable on slippery ground. In one instance, the machine glided over seemingly solid terrain that concealed a water hole covered by snow without losing its balance. According to reports, while the robot moved at a significantly reduced speed in particularly challenging sections, it never lost its stability. It should be noted, however, that independent third-party verification of specific performance data is currently limited.
Deep Robotics emphasizes that the modified Lynx S10 is currently still in the alpha stage and is not a finished production model. The insights and data gathered from this expedition will be directly incorporated into the production development process. The stated goal is to create a reliable tool for scientific expeditions or rescue missions that can be used to explore inhospitable, remote, or dangerous areas without exposing people to unnecessary risks. (mc)
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.