Autonomous mobile robots and automated guided vehicles (AGVs) integrate power electronics, control systems, and sensor technology onto a platform that is constantly in motion. This poses challenges for connection technology. The characteristics that are critical for each interface depend on its function within the system architecture.
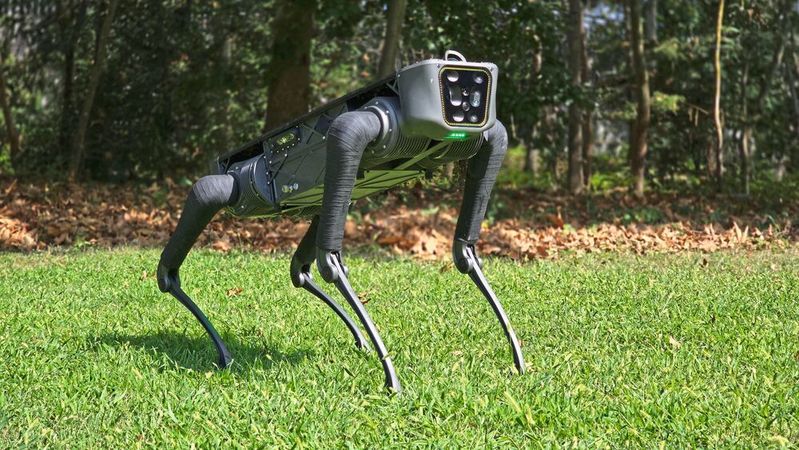
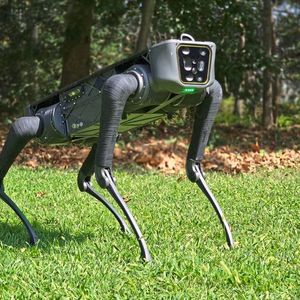
Robotics: In AMR applications, connection technology must reliably transmit power, signals, and data despite vibration and shock loads—in very confined spaces and in a way that allows for regular maintenance.
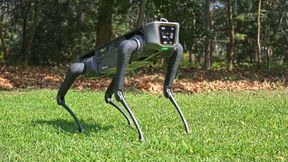
(Image: Hyperever)
Unlike stationary automation systems, automated guided vehicles (AGVs) and autonomous mobile robots (AMRs) operate under constantly changing mechanical loads. Traveling over factory floors, expansion joints, or ramps generates vibrations, as do acceleration and braking maneuvers. Added to this are impact loads when docking at charging stations or during load changes. These forces directly affect printed circuit boards, wiring harnesses, and connectors.
Compact and medium-sized systems often use 24- or 48-volt DC power supplies with additional power rails for sensors, controllers, and safety devices. At the same time, computing power is distributed across multiple electronic modules. While a central computer handles navigation and environmental sensing, decentralized modules control the drive systems, battery management, safety functions, or actuators.
LiDAR, cameras, and diagnostic interfaces are increasingly communicating via Ethernet-based networks. As a result, not only is the number of electrical connections growing, but their functions also vary considerably: High-current paths supply motor controllers and power electronics, while sensitive sensors require stable signals and low-interference data channels. The selection of a connector is therefore not based solely on current-carrying capacity or the number of contacts, but on the mechanical and electrical constraints of the respective function.
Typical causes of failure develop gradually. Micro-movements between contact surfaces can cause fretting corrosion and increase contact resistance. In power connections, this leads to additional heating and voltage drop; in data lines, it results in unstable connections or communication errors. Equally critical are inadequately secured connectors or missing strain reliefs, because cable movements transmit forces directly to contacts, crimp connections, or solder joints.
Designing Contacts Correctly
The stresses described directly determine the design characteristics of a connector. The primary focus is on contact stability. Multi-finger contacts create multiple parallel contact points and maintain the electrical connection even when vibrations or slight relative movements temporarily affect individual contact points. This reduces the risk of intermittent connections and increasing contact resistance.
Equally important is the spring force of the contacts. It must continuously compensate for vibrations, but must neither make the mating process more difficult nor increase wear. Contact geometry, spring material, and surface coating must therefore be considered as a single design unit. Gold-plated contact surfaces help maintain stable electrical properties over long periods of operation, particularly with low signal currents.
Operational safety also requires a reliable locking mechanism. Screw connections or similar securing systems prevent connectors from coming loose due to mechanical stress or service work. Strain reliefs also prevent forces from the wiring harness from acting directly on contacts or circuit boards.
As data rates increase, signal integrity is becoming a key focus. Ethernet connections for cameras, LiDAR, or diagnostic data cannot be considered in isolation. It is the interaction between connectors, printed circuit boards, cables, shielding, and grounding that determines the transmission quality. At the same time, motor drives, DC/DC converters, and charging devices influence the electromagnetic environment. As a result, a clean shielding connection and defined return current paths are just as important as the actual contact technology.
Thermal boundary conditions are also taken into account in the design. The permissible current load depends on the conductor cross-section and contact configuration, as well as on the ambient temperature and load profile. Developers should therefore evaluate actual peak loads rather than relying solely on the rated current of individual contacts.
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.
The selection of a connector is thus evolving from a decision about a single component to a balancing act involving mechanical, electrical, and thermal properties within the architecture of the overall system.
From the Sensor to the DC Bus
The requirements within an AGV or AMR vary considerably depending on the function. Accordingly, there is no universal connector solution used in practice; instead, the selection is based on current load, installation space, data transmission, and the mechanical stress on the respective assembly.
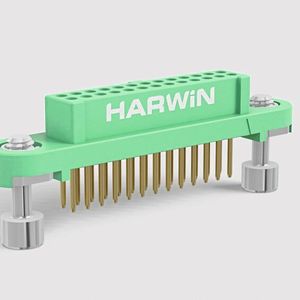
Sensors, cameras, LiDAR units, and embedded controllers require, above all, compact dimensions and low mass. On moving sensor heads, every additional gram increases the mechanical load. At the same time, the connectors must withstand vibrations and repetitive movements over the long term. Compact, high-reliability connectors such as Harwin’s Gecko series are well-suited for this purpose. Multi-finger contacts, screw locks, and their compact design ensure stable signal transmission even under dynamic loads.
For interfaces that must carry higher currents in addition to signals, the so-called Mix-Tek versions within the Data-mate family are ideal. They combine different contact types in a single housing. This allows developers to integrate power and signal contacts into a single interface in a space-saving manner, rather than using separate connectors.
Use Case: High Currents in a Confined Space
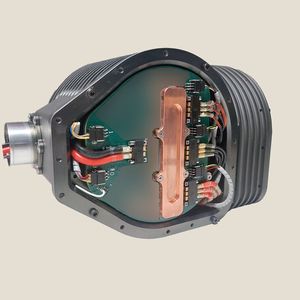
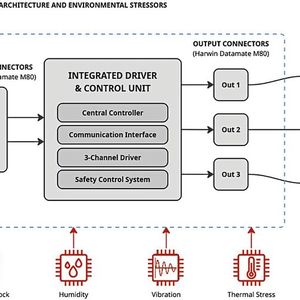
Istanbul-based robotics developer Hyperever demonstrates how this requirement plays out in a real-world mobile platform. Its four-legged mobile robot, called Proteo, uses an M80 connector from Harwin’s Datamate family to supply power to the drive system. According to Hyperever, the decisive factor in choosing the M80 was primarily the ratio of current-carrying capacity to required installation space, as well as the ability to combine power and signal contacts in a compact connector. This is particularly relevant in drive systems, where developers must transmit high currents while mechanical components, electronics, and cabling compete for limited installation space.
In addition to electrical power density, the engineers placed great importance on the mechanical design of the interface. M80 variants are available with floating jackscrews—floating-mounted fastening screws. Their design allows for some play, which facilitates the alignment of the connector parts and accommodates positional tolerances during assembly. Once tightened, the jackscrews mechanically secure the mated connection. For a platform like Proteo, whose motion repeatedly subjects the electronics and cabling to mechanical stress, a connection secured in this way is essential.
However, selecting components based solely on data sheet specifications is not sufficient. Hyperever has already evaluated the connection’s thermal performance within the overall system. Mechanical testing is still pending. This distinction is particularly important for high-current interfaces: rated current, contact resistance, and permissible temperature form the basis for preliminary selection; however, the actual heat generation also depends on pin configuration, conductor cross-section, ambient temperature, heat dissipation, and installation conditions. Therefore, only verification in the actual assembly can show whether the selected interface has sufficient thermal headroom under the intended operating conditions.
Proteo moves on four legs rather than on wheels, which distinguishes it structurally from traditional AGVs and many industrial AMRs. However, the underlying requirements for connectivity technology remain similar: electrical power density, installation space, and mechanical stresses must all be taken into account. The load profile of the respective assembly therefore determines which connector family is suitable. For moderate power currents, this might lead to the M300, for example; for particularly high-current interfaces, the Kona series comes into focus.
Board-to-board connections occupy a special position. Densely populated electronic modules are sensitive to manufacturing tolerances or slight warping during assembly. Floating connectors such as Flecto compensate for positional deviations between printed circuit boards in multiple axes, thereby reducing mechanical stress on contacts and circuit boards. This facilitates the assembly of compact computer and control modules and increases their long-term reliability.
The selection is therefore consistently based on the component’s function within the system architecture: The key factors are the interaction of contact technology, current-carrying capacity, latching, installation space, and mechanical stress.
Reliability is in the Details
Connector failures are often not caused by the contacts themselves; rather, they frequently result from improper integration. Effective strain relief, for example, prevents forces from cable movement from acting directly on crimp connections, contacts, or solder joints. Likewise, PCB connectors should not be relied upon to support heavy or stiff cable harnesses on their own. Additional fasteners relieve stress on the connection and extend its service life.
Cable routing is equally important. Power cables for drive systems or charging equipment should be routed at a sufficient distance from Ethernet, camera, or encoder signals. A properly defined shield connection and ground path reduce electromagnetic interference and stabilize data transmission.
Power connections also require a thermal analysis under actual operating conditions. Pin configuration, conductor cross-section, ambient temperature, and load profile all influence the temperature rise, as do short-term current spikes that occur during acceleration or when lifting a load. The design should therefore be based on the actual operating profile.
After all, locks only function properly if they are fully installed and remain easily accessible for servicing. Unique coding also simplifies installation and maintenance and prevents incorrect connections.
Conclusion: From Component to Architecture
With increasing autonomy, a growing number of sensors, and rising power density, connector technology continues to gain in importance. Connectors have long since ceased to merely transmit power or signals; they also influence signal integrity, thermal behavior, and maintainability. For developers, the focus is shifting from the individual connector to its role within the system architecture. Only the coordinated design of contact technology, mechanics, and integration creates the conditions for the long-term, reliable operation of mobile robotics.