The Technical University of Munich (Germany) uses Sensojoints actuators from Sensodrive to build deformable, flexible robots that are not moved by traditional joints, but by ropes or cables. The research team is setting new standards in the modeling and control of cable-actuated continuum robots.
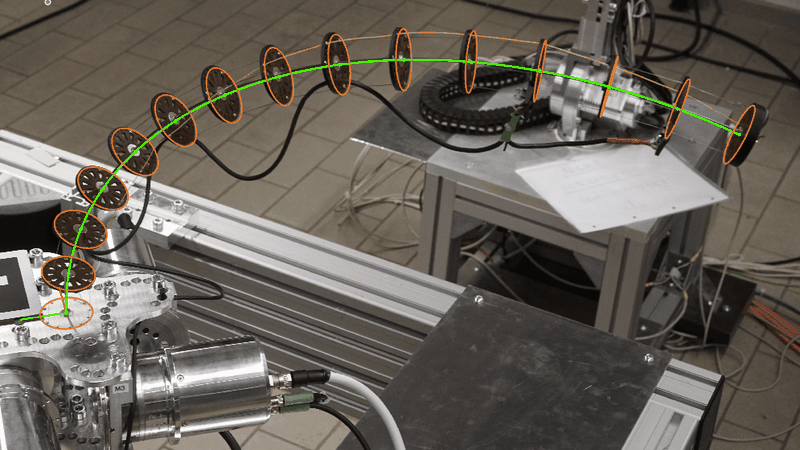
The research team at the Technical University of Munich measures and controls the tendon forces on the robot. The aim of the research project is to develop new control concepts.
(Image: TU Munich)
Continuum robots are an exciting robotic technology: their continuously deformable structure opens up new application possibilities—for example in medical technology, for inspection tasks in confined environments or in safety-critical human-robot interactions. At the same time, they pose enormous challenges for research and development, particularly in terms of modeling, state estimation and control.
The Chair of Control Engineering at the Technical University of Munich (TUM) addressed precisely this challenge in a current research project. The aim was to build such a cable-actuated continuum manipulator that would make it possible to measure and directly control tendon forces with high precision—as the basis for innovative model-based control and observer concepts. The research team used Sensojoints actuators from Sensodrive for this purpose.
An Experimental Robot for New Scientific Findings
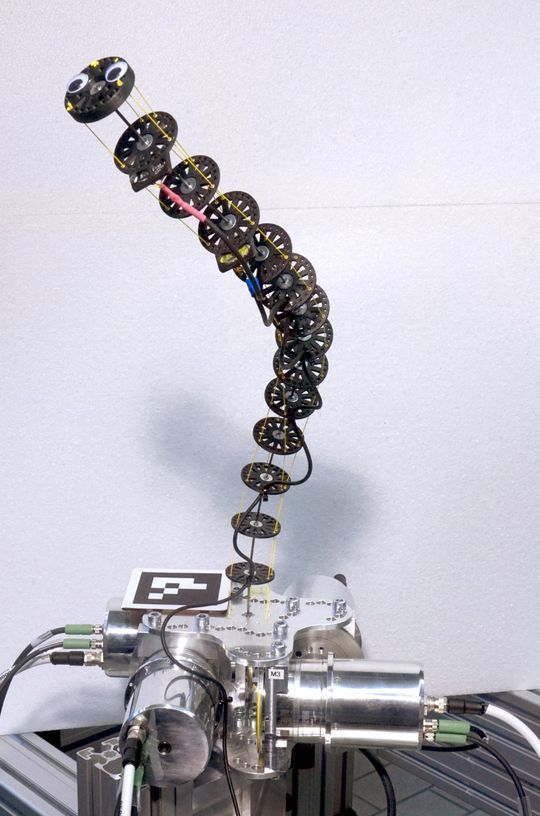
Experimental setup of the continuum robot system with the new actuators: Who is watching whom?
(Image: TU Munich)
The project focused on the development of an experimental robot system with an elastic backbone and cable-based actuation. Unlike conventional industrial robots, the continuum robot does not have discrete joints, but deforms continuously over its entire length. The movement is generated by several tendons, the tension of which must be adjusted in a targeted manner.
For research, this means that realistic models can only be validated, conditions reliably estimated and external faults detected if the output-side torques and forces are precisely measured and controlled. This is precisely where the limits of previously used drive solutions lay, which only allowed indirect torque control via motor currents.
Actuators As An Enabler for the Research Project
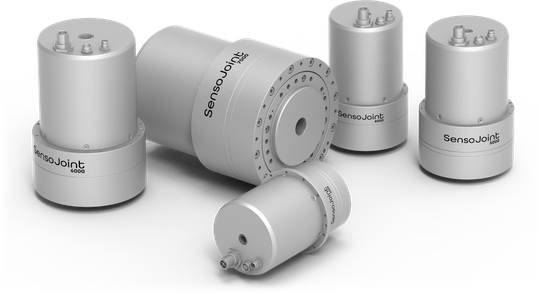
The TUM research team opted for the Sensojoints from Sensodrive for the new test setup. The decisive factor was the overall package of direct, high-resolution torque measurement, powerful advanced torque control and an open and transparent system architecture.
Actuators from Sensordrive are installed in the new test setup.
(Image: Sensordrive)
Only through the direct control of the output-side torque—including compensation of gearbox effects such as friction or ripple—was it possible to set up the continuum robot so quickly and use it productively. Integration was also a success factor: thanks to the documentation and support for common standards such as CiA402, the hardware and software could be prepared before delivery. This shortened the time from planning to commissioning.
Continuum Robot Delivers Precise Measurement Data
The added value of the actuators became apparent during operation: the precise torque measurement on the output side enabled a previously unattainable analysis of the system behavior. At the same time, effects that falsified previous test setups—such as uncompensated gear friction—could be effectively eliminated.
The experimental data obtained in this way formed the basis for the validation of new discrete modeling and observer approaches and were incorporated directly into a scientific publication. The continuum robot thus became not only an experimental setup, but also a reliable reference system for further research.
Partnership With A Focus on the Research Question
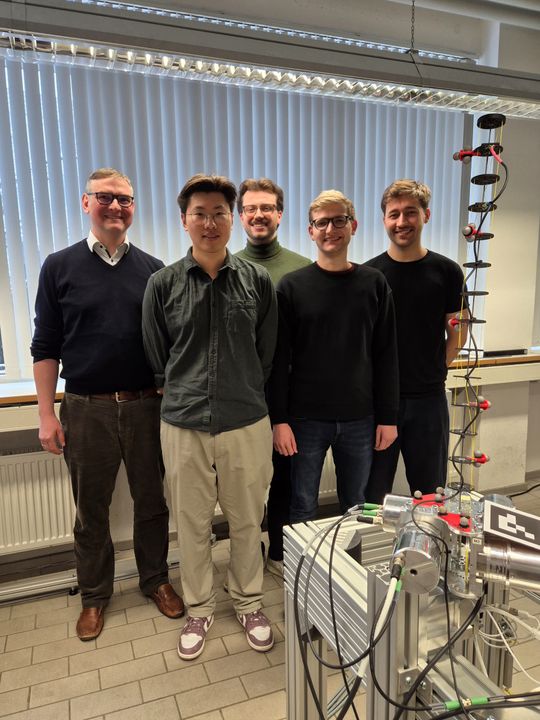
The working group at the Technical University of Munich (from left) Professor Paul Kotyczka, Le Zhang, Stephan Kohlhaas, Maximilian Herrmann and Leander Pfeiffer with the continuum robot.
(Image: TU Munich)
The TUM team benefited from the technical advice, accessibility and transparent documentation: instead of a black box solution, the scientists had a system at their disposal whose behavior they could understand in detail and use in a targeted manner. This proved to be an advantage in a scientific context.
From the perspective of the project managers, the supplier's interest in the research question was particularly important for the collaboration. Solutions were not "sold", but developed together—with the clear aim of creating the best possible technical basis for research.
Future Prospects: From Modeling to Control
Following successful work on model identification and state estimation, the focus of the project is now increasingly shifting towards model-based control of the continuum robot. The actuators used will continue to play a central role in this. The project shows how standardized, torque-controlled drive solutions can be used to implement complex research platforms in the shortest possible time—without compromising on precision or quality.
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.