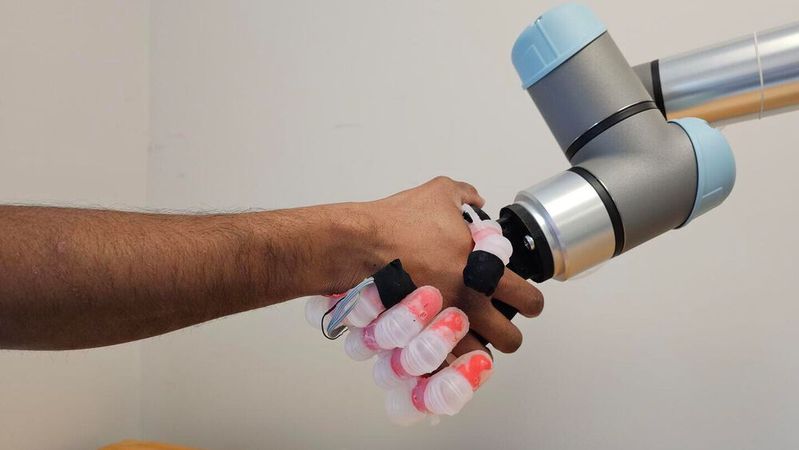
Engineers at Johns Hopkins University have developed a prosthetic hand that can grasp stuffed animals, water bottles and other everyday objects like a human by adjusting its grip so that it does not damage or mishandle the objects. To enable a more precise and natural grasp, the engineers used technologies such as 3D printing.
The aim of the researchers at John Hopkins University was to develop a more natural prosthesis that functions and feels like a lost limb.
(Image: University Johns Hopkins)
Reaching for a bottle, a ball or even a stuffed animal may seem harmless, but for people with amputations, these everyday actions present a challenge. The prosthesis developed at John Hopkins University could change this by automatically adapting its grip to the object being held. "The goal from the beginning was to develop a prosthetic hand that we model based on the physical and sensory capabilities of the human hand - a more natural prosthesis that functions and feels like a lost limb," said Sriramana Sankar, a Johns Hopkins doctoral student in biomedical engineering who led the work. "We want to give people who have lost their upper limbs the ability to interact safely and freely with their environment, to feel and hold their loved ones without fear of hurting them.
Tactile sensors inspired by the layers of human skin
The prosthesis consists of a multi-finger system with rubber-like polymers and a rigid 3D-printed inner skeleton. Its three layers of tactile sensors, inspired by the layers of human skin, allow it to sense and distinguish objects of different shapes and textures, rather than just recognizing touch. Each of its soft, air-filled finger joints can be controlled with the muscles of the forearm, according to Sankar, and machine learning algorithms focus the signals from the artificial tactile receptors to create a realistic sense of touch. "The sensory information from his fingers is translated into the language of nerves to provide lifelike sensory feedback through electrical nerve stimulation," says Sankar.
We combine the strengths of both rigid and soft robotics to imitate the human hand.
Sriramana Sankar
Prosthesis adjusts handle as required
In the laboratory, the hand identified and manipulated 15 everyday objects, including delicate stuffed animals, dishwashing sponges and cardboard boxes, as well as pineapples, metal water bottles and other more robust objects. In the experiments, the prosthetic hand achieved the best performance compared to the alternatives: it handled the objects with 99.69% accuracy and adjusted its grip when necessary to avoid mishaps. The best example was when it picked up a thin, fragile plastic cup filled with water with just three fingers without damaging it.
"We combine the strengths of both rigid and soft robotics to mimic the human hand," says Sankar. "The human hand is neither completely rigid nor purely soft - it is a hybrid system in which bones, soft joints and tissue work together. This is exactly what we want to achieve with our hand prosthesis. This is new territory for robotics and prosthetics, which have not yet made full use of this hybrid technology. It's about giving a firm handshake or picking up a soft object without fear of crushing it."
Our system is neurally inspired - it models the hand's touch receptors to generate nerve-like messages so that the 'brain' of the prosthesis, i.e. the computer, understands whether something is hot or cold, soft or hard, or slipping out of the grip.
Nitish Thakor
Hand prosthesis uses muscle signals from the forearm
The bio-inspired technology enables the hand to function in this way by using muscle signals from the forearm, like most prosthetic hands. These signals bypass the brain and nerves and allow the hand to flex, release or respond based on its sense of touch. The result, according to Nitish Thakor, professor of biomedical engineering at Johns Hopkins University, is a robotic hand that intuitively "knows" what it is touching, much like the nervous system does.
"When you hold a cup of coffee in your hand, how do you know you're about to drop it? Your palm and fingertips send signals to your brain that the cup is about to slip," says Thakor. "Our system is neurally inspired - it models the hand's touch receptors to generate nerve-like messages so that the 'brain' of the prosthesis, i.e. the computer, understands whether something is hot or cold, soft or hard, or slipping out of grip."
Breakthrough for hybrid robot technology
The research represents an early breakthrough for hybrid robot technology that could transform both prosthetics and robotics, but further work is needed to refine the system, Thakor said. Future improvements could include stronger gripping forces, additional sensors and industrial-grade materials. "This hybrid dexterity is not just important for the next generation of prosthetics," Thakor said. "It's what the robotic hands of the future will need, because they won't just be handling large, heavy objects. They will also have to work with delicate materials such as glass, fabric or soft toys. That's why a hybrid robot designed like the human hand is so valuable - it combines soft and rigid structures, just like our skin, tissue and bones."
Date: 08.12.2025
Naturally, we always handle your personal data responsibly. Any personal data we receive from you is processed in accordance with applicable data protection legislation. For detailed information please see our privacy policy.
Consent to the use of data for promotional purposes
I hereby consent to Vogel Communications Group GmbH & Co. KG, Max-Planck-Str. 7-9, 97082 Würzburg including any affiliated companies according to §§ 15 et seq. AktG (hereafter: Vogel Communications Group) using my e-mail address to send editorial newsletters. A list of all affiliated companies can be found here
Newsletter content may include all products and services of any companies mentioned above, including for example specialist journals and books, events and fairs as well as event-related products and services, print and digital media offers and services such as additional (editorial) newsletters, raffles, lead campaigns, market research both online and offline, specialist webportals and e-learning offers. In case my personal telephone number has also been collected, it may be used for offers of aforementioned products, for services of the companies mentioned above, and market research purposes.
Additionally, my consent also includes the processing of my email address and telephone number for data matching for marketing purposes with select advertising partners such as LinkedIn, Google, and Meta. For this, Vogel Communications Group may transmit said data in hashed form to the advertising partners who then use said data to determine whether I am also a member of the mentioned advertising partner portals. Vogel Communications Group uses this feature for the purposes of re-targeting (up-selling, cross-selling, and customer loyalty), generating so-called look-alike audiences for acquisition of new customers, and as basis for exclusion for on-going advertising campaigns. Further information can be found in section “data matching for marketing purposes”.
In case I access protected data on Internet portals of Vogel Communications Group including any affiliated companies according to §§ 15 et seq. AktG, I need to provide further data in order to register for the access to such content. In return for this free access to editorial content, my data may be used in accordance with this consent for the purposes stated here. This does not apply to data matching for marketing purposes.
Right of revocation
I understand that I can revoke my consent at will. My revocation does not change the lawfulness of data processing that was conducted based on my consent leading up to my revocation. One option to declare my revocation is to use the contact form found at https://contact.vogel.de. In case I no longer wish to receive certain newsletters, I have subscribed to, I can also click on the unsubscribe link included at the end of a newsletter. Further information regarding my right of revocation and the implementation of it as well as the consequences of my revocation can be found in the data protection declaration, section editorial newsletter.